Unitree G1-D Humanoid Robot — End-to-End Platform for Embodied AI
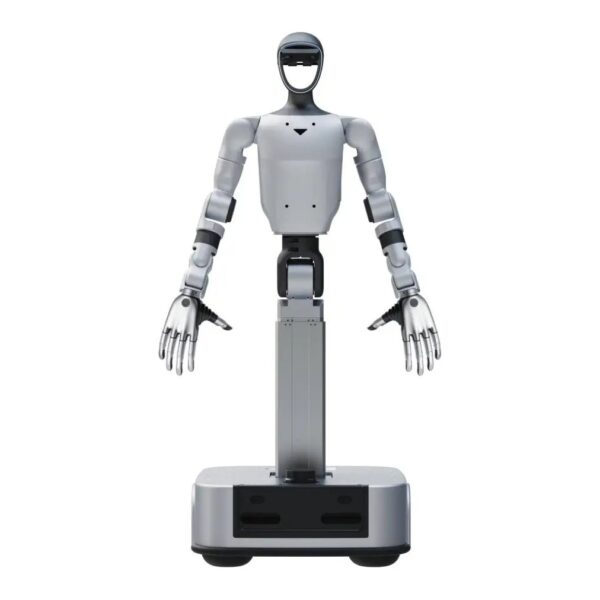
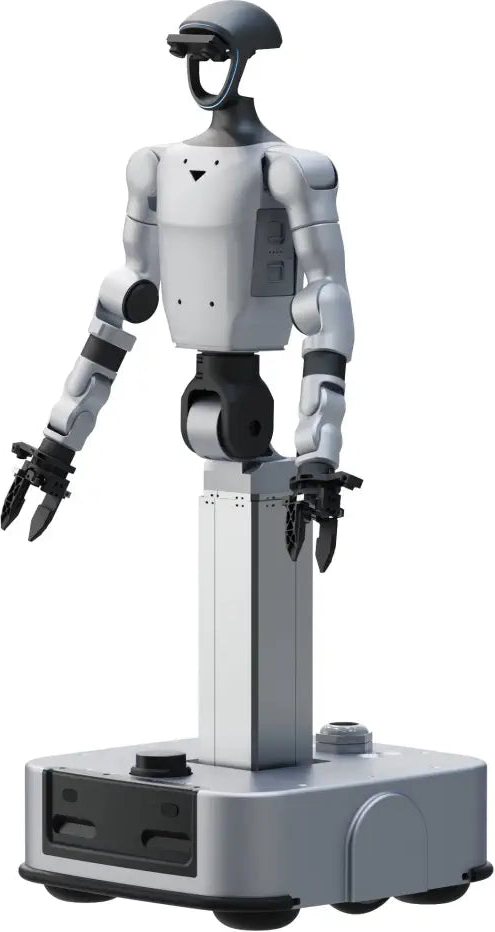
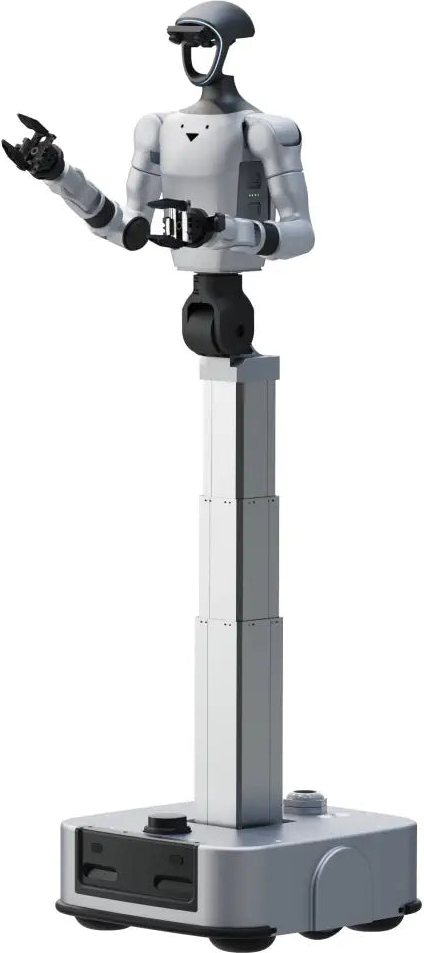
The Unitree G1-D is a dual-arm humanoid built to collect robot data, train models and deploy them on real hardware, all on one platform. It pairs a 7-DOF-per-arm upper body on a lifting column with Unitree’s data acquisition and model training tools. Choose the G1-D Standard on a fixed base, or the G1-D Ultimate with a mobile chassis that drives at up to 1.5 m/s.
One platform: robot, data and training
The G1-D brings three core parts together:
- High-performance humanoid robot with Unitree’s own actuators, gearboxes, encoders and sensors.
- Data acquisition tools covering collection, processing, labelling, review and data asset management.
- Model training and inference tools with distributed training, custom model development and deployment, supporting the major open-source frameworks.
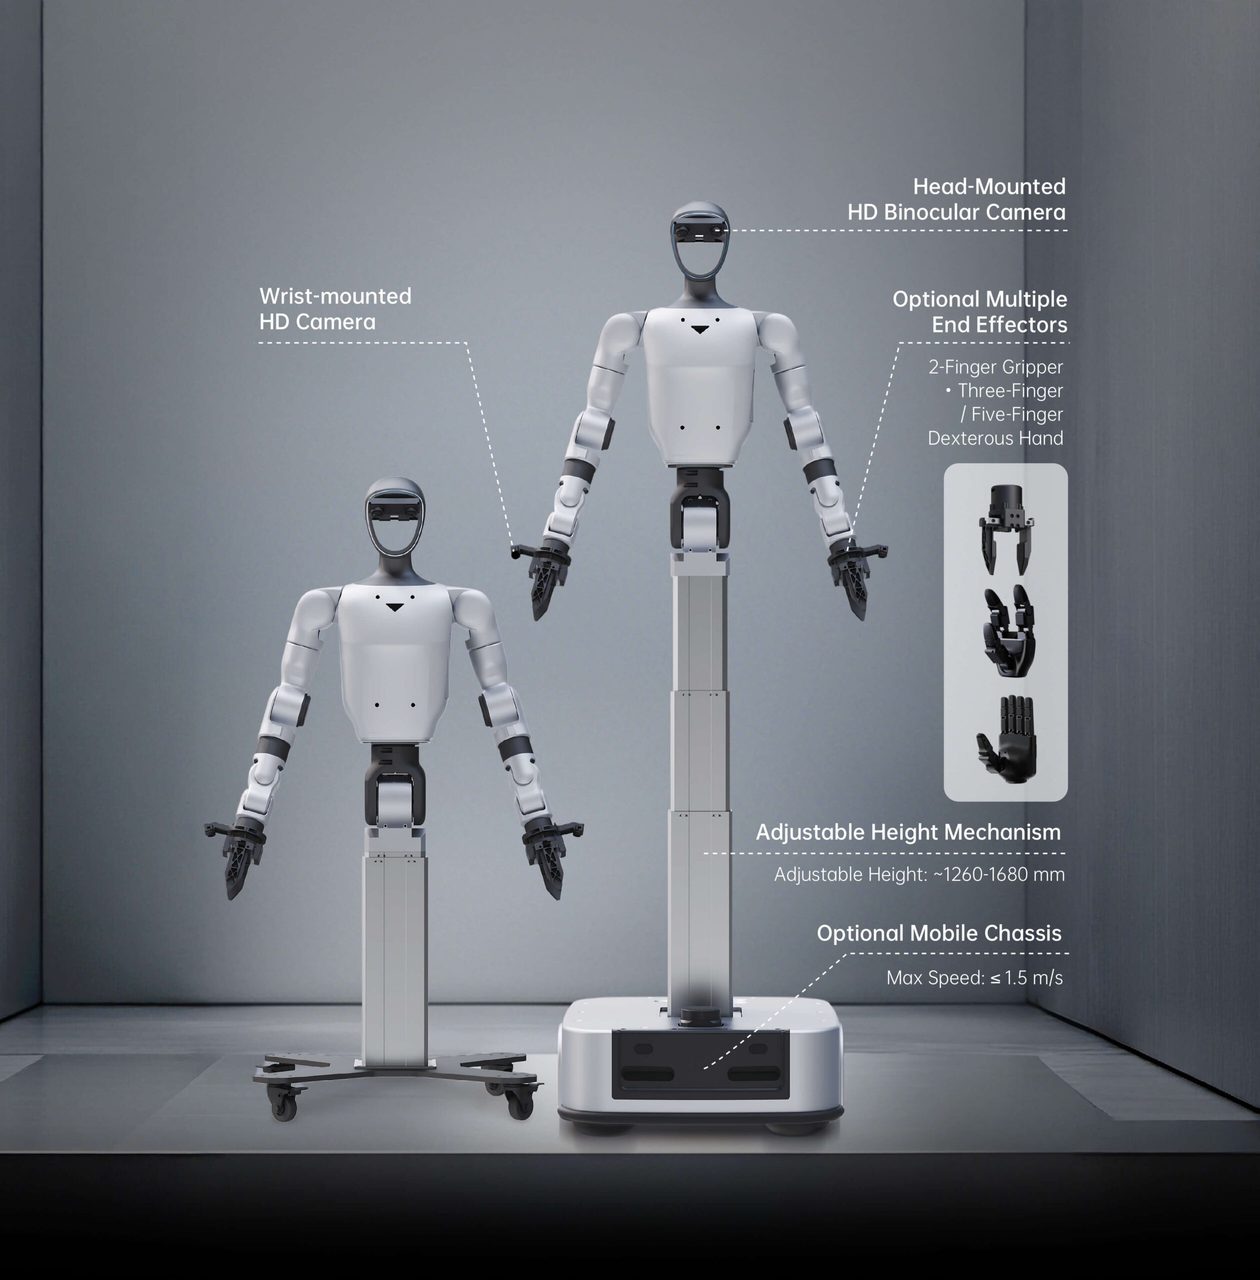
Higher-DOF robot platform
Up to 19 degrees of freedom before the end effector:
- Arms: 7 × 2
- Waist: 2
- Column: 1
- Mobile base: 2 (Ultimate)
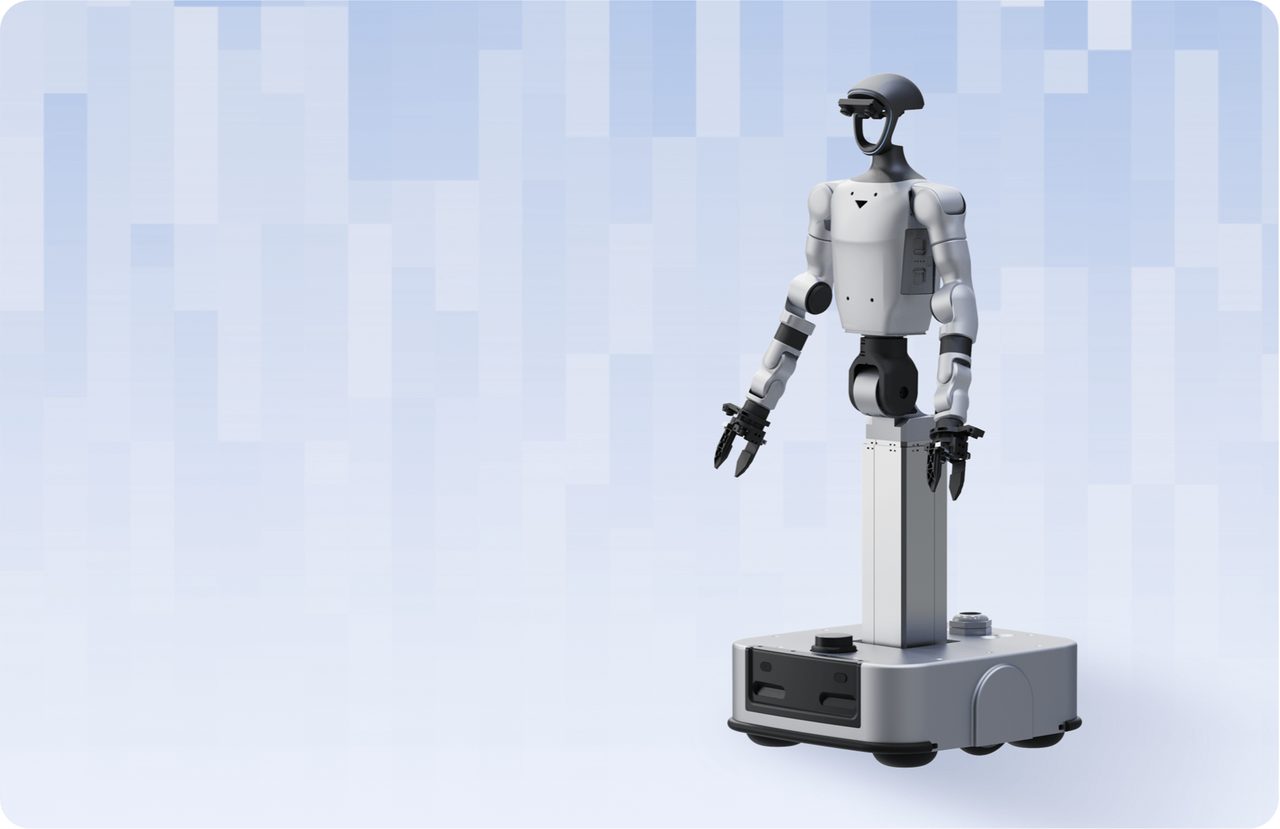
Expanded operational workspace
The lifting column adjusts the robot from 1260 mm to 1680 mm at about 60 mm/s. With a waist that turns ±155° and bends from −2.5° to +135°, the arms reach from the floor up to a working height of about 2 m.
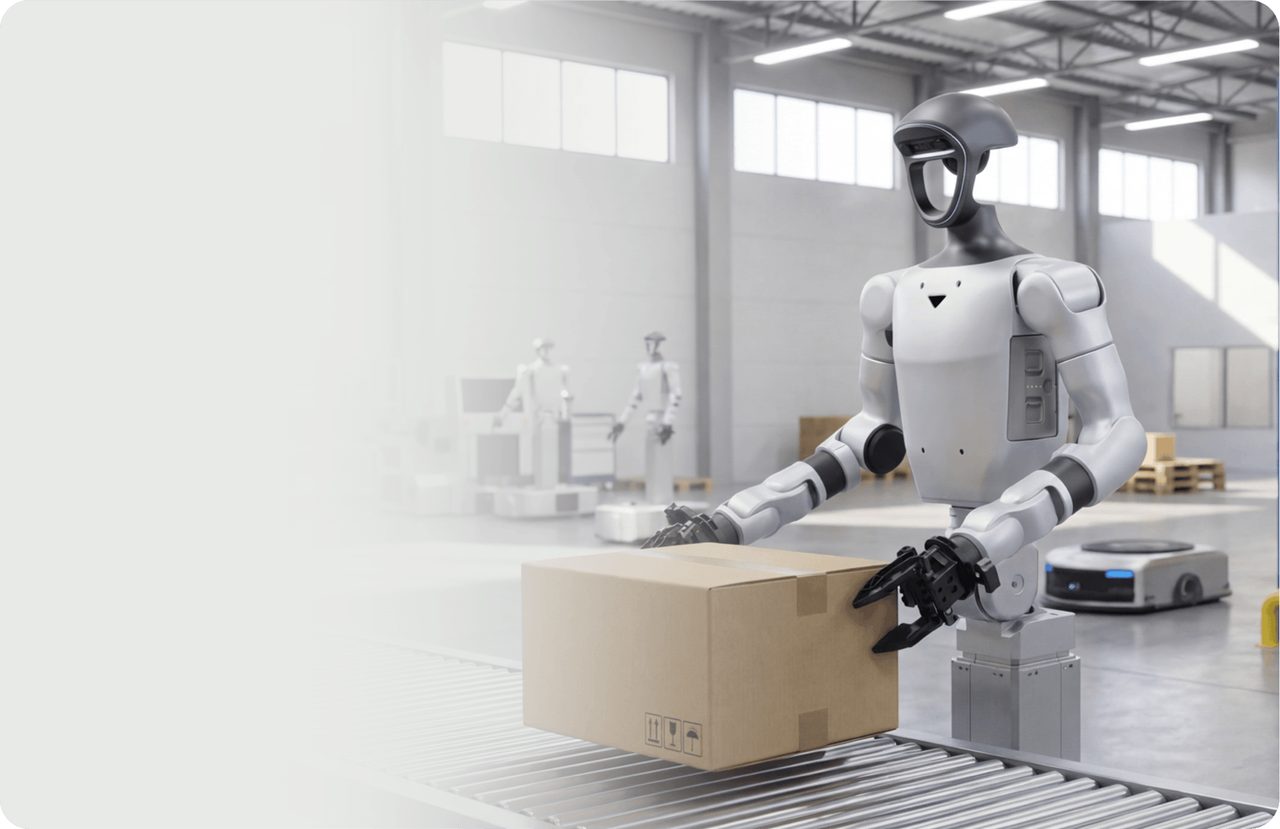
Lower-latency control response
Fast, responsive control makes teleoperation feel natural. An operator wearing the PICO VR teleoperation kit drives both arms in real time, which is how high-quality demonstration data is recorded.
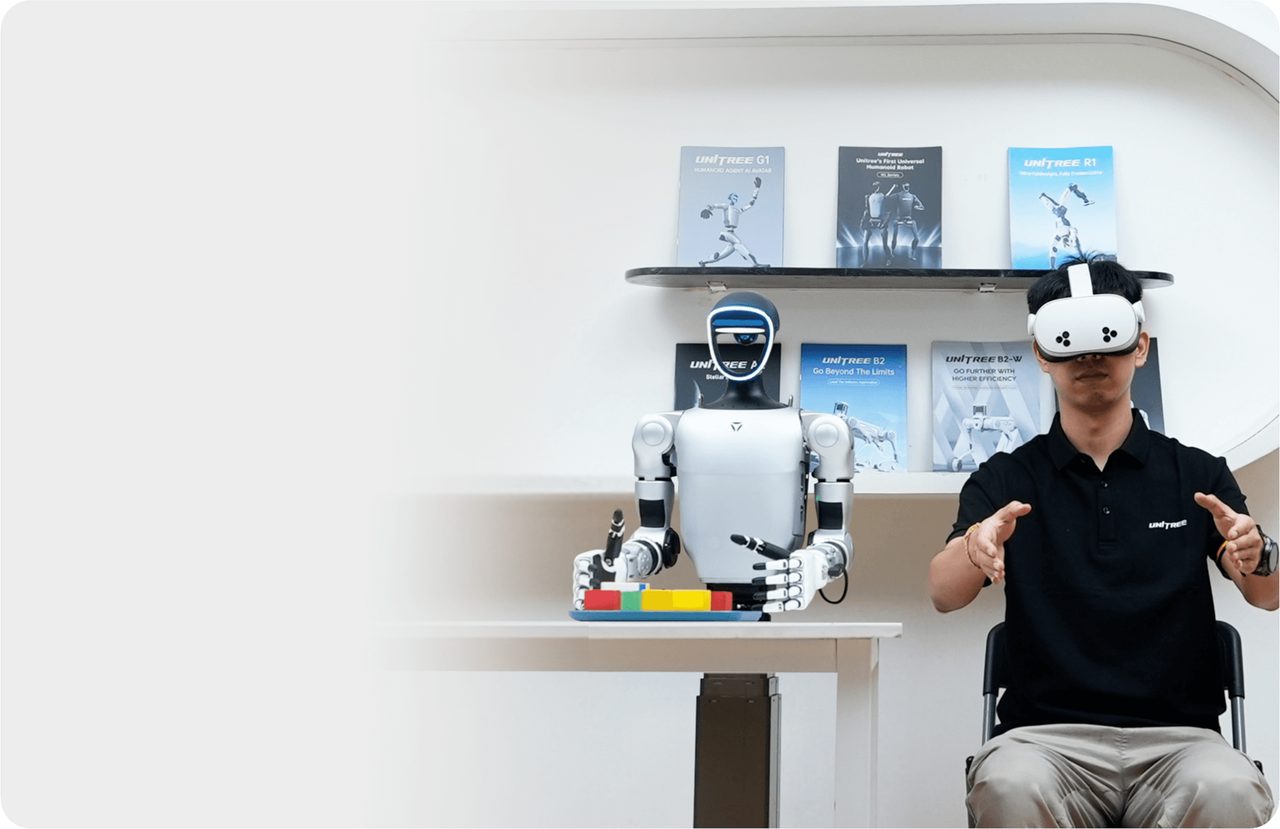
Data collection in action
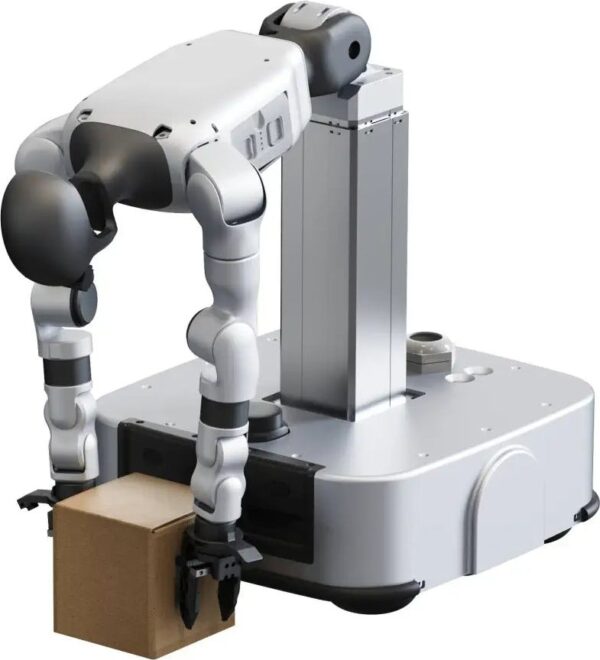
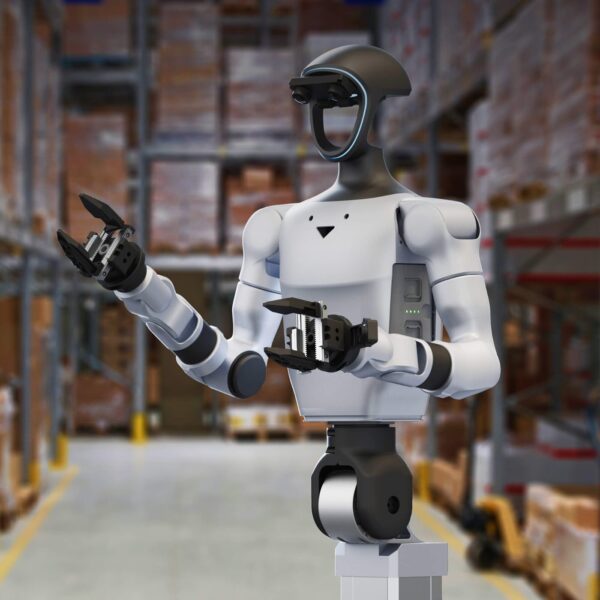
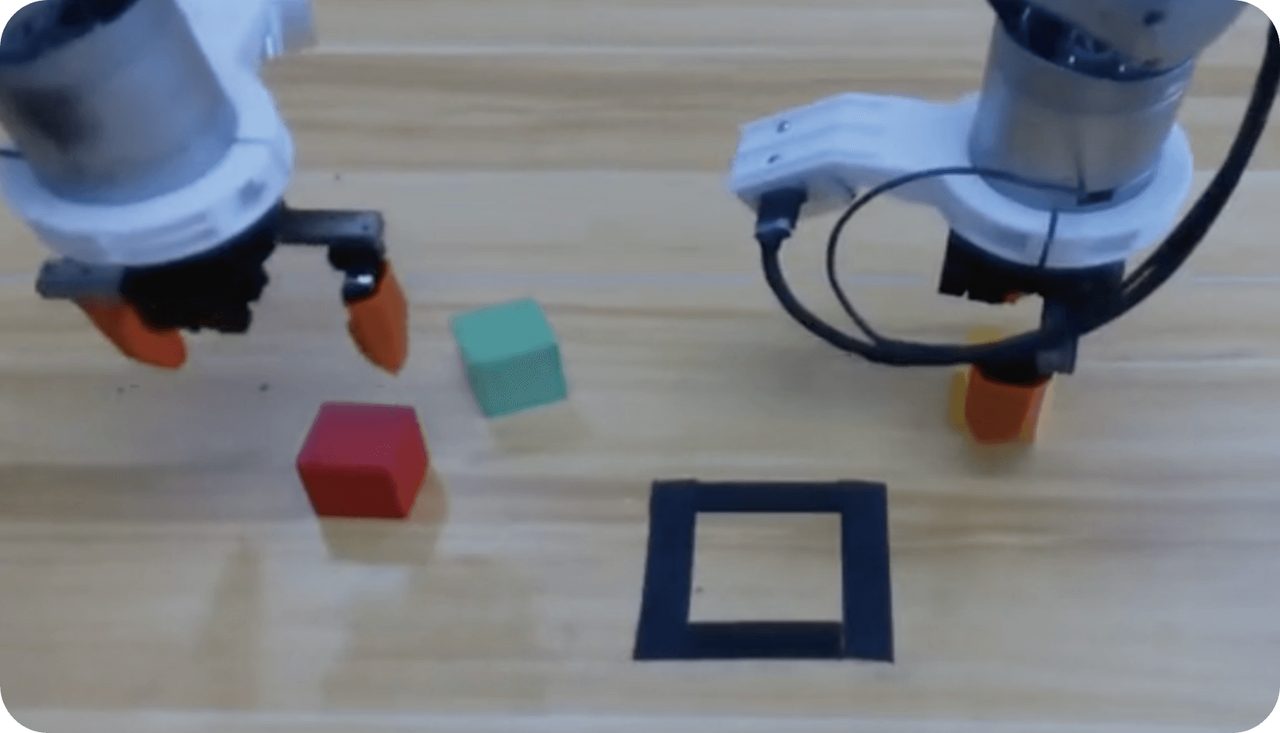
The head binocular camera and two wrist HD cameras record what the robot sees while it handles real objects. Each session becomes training data for your own manipulation policies.
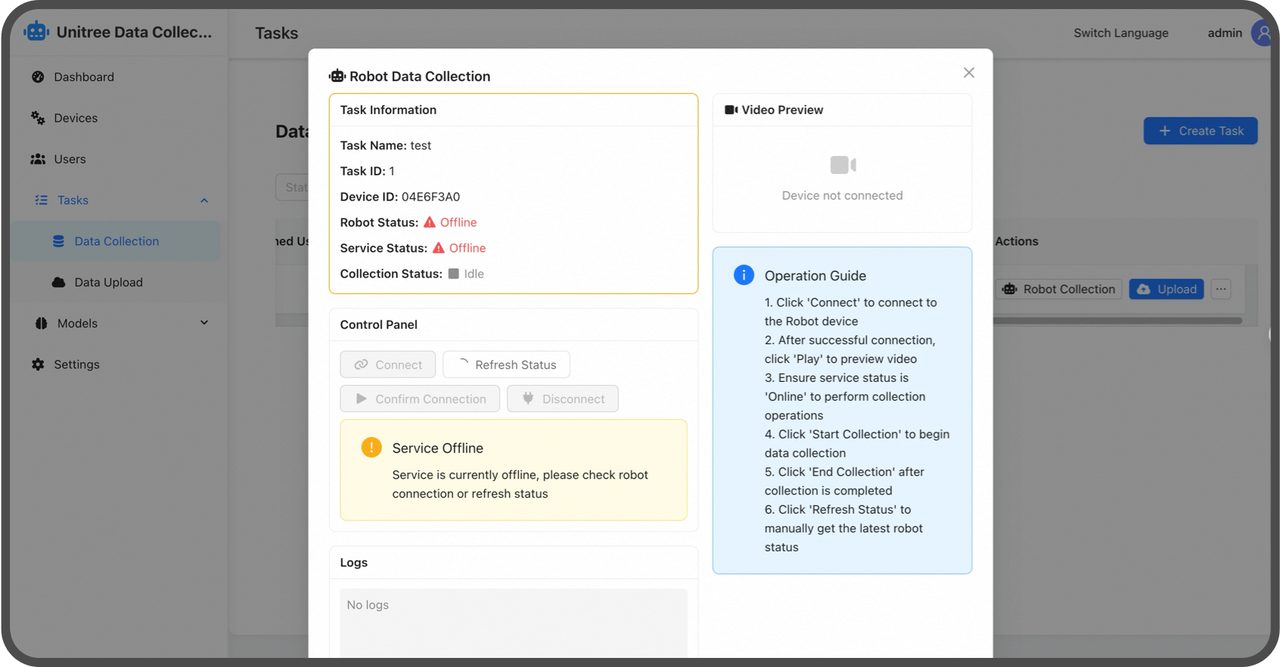
Streamlined data acquisition tools
- Visual template management: projects, task allocation, progress tracking and status in one place. Templates create collection tasks in one click.
- Flexible configurations: works across robot platforms and end effectors, and standardises data for training.
- High-concurrency architecture: built for hundreds of robots collecting data at the same time.
- 24/7 online collection: high-availability service with export to mainstream training formats.
Pipeline: create tasks → edit and assign → acquire and annotate → upload and review → store → export.
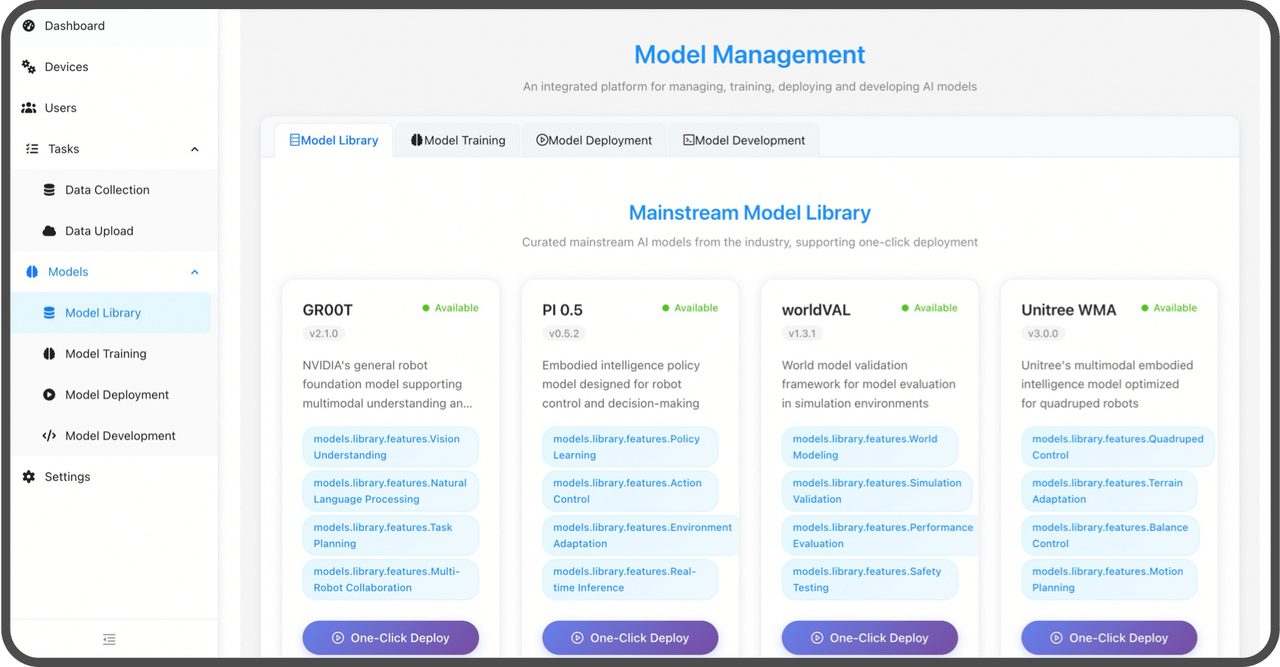
Model training and inference tools
- Mainstream model support: built-in community datasets and integration with open-source models such as PI and GR00T.
- Simulation environment: a high-fidelity 3D asset library for building test scenes and validating algorithms.
- Rapid deployment: out of the box, with one-click training and a direct path from algorithm to real robot.
- Distributed training: elastic compute scheduling with up to 90% GPU utilisation.
Pipeline: choose model → configure training → monitor → edit parameters → test in simulation → export and deploy.
UnifoLM-WMA-0 world-model–action framework
Unitree’s open-source world-model–action architecture for general-purpose robot learning across robot types.
- Decision-making mode: predicts how the robot will interact with its surroundings, helping the policy produce more accurate actions.
- Simulation mode: acts as an interactive simulator that generates realistic feedback and synthetic training data.
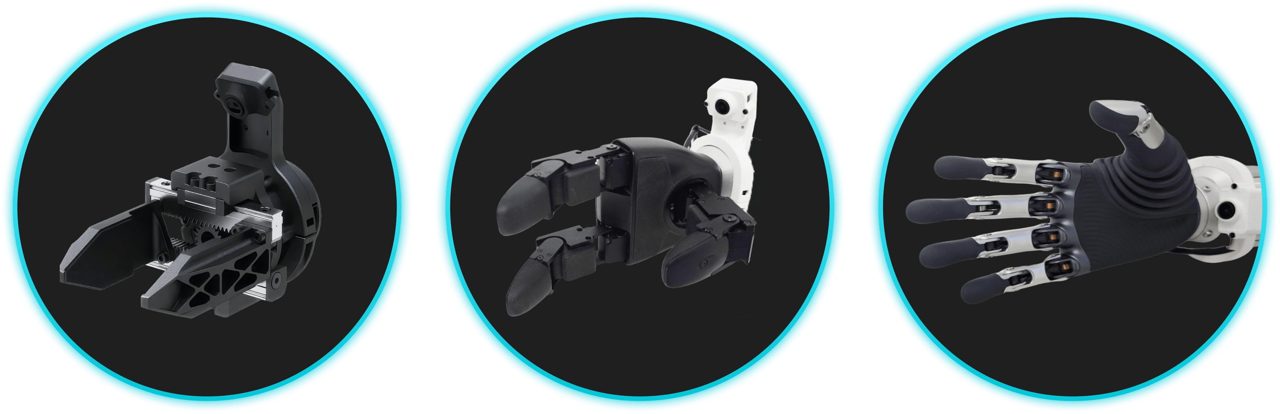
End effector options
Pictured left to right:
- Dex1-1 two-finger gripper: 5–120 N adjustable grip, 90 mm stroke, 0.24 s close. Fast and repeatable for pick-and-place.
- Dex3-1 three-finger dexterous hand: 7 DOF per hand, with or without tactile sensing (33 sensors).
- BrainCo Revo 2 five-finger hand: 6 DOF, 11 joints and 0.1° repeatability, with an optional tactile edition.
Every dexterous hand option includes a 160° RGB wrist camera.
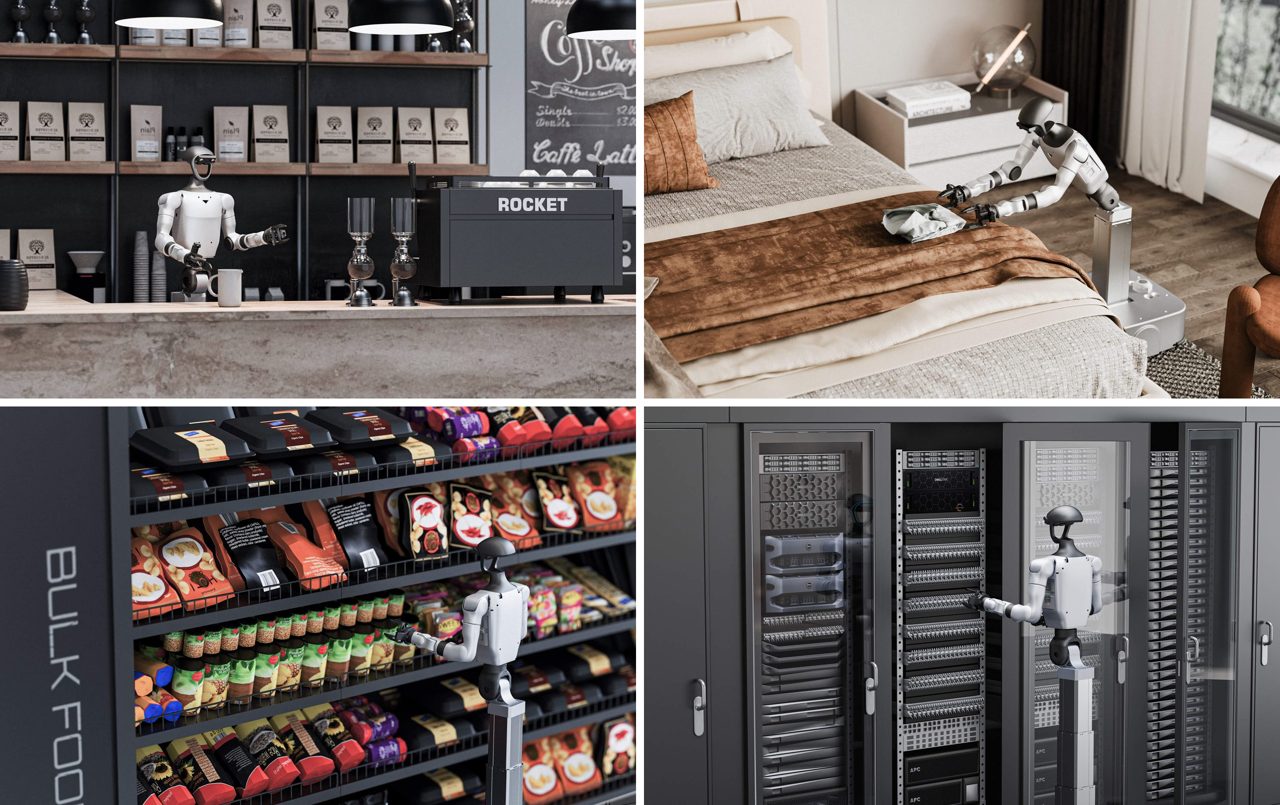
Application scenarios
- Service: cafés, front desks and customer service.
- Life: home and care tasks such as making a bed.
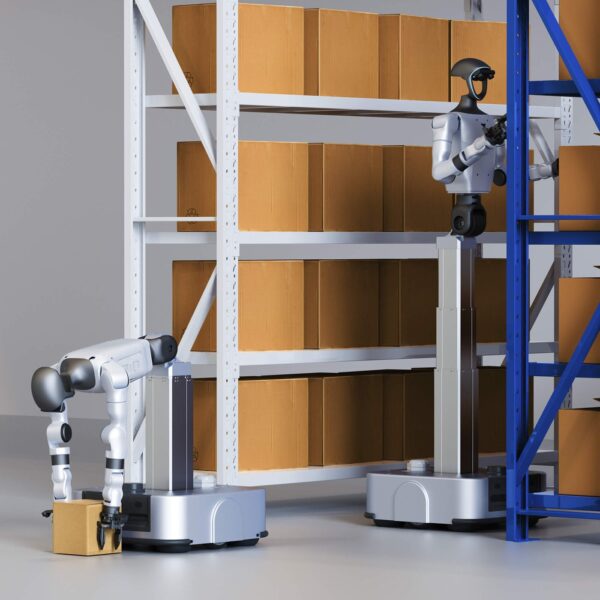
- Retail: shelf picking and restocking.
- Industry: data centres, warehouses and factory stations.
It is also a strong fit for innovation centres, universities and research labs. For a walking humanoid, see the Unitree G1 Humanoid Robot.
Unitree G1-D Standard vs Ultimate — Specifications
| Parameter | G1-D Standard | G1-D Ultimate |
|---|---|---|
| Dimensions (min. column height) | 1260 × 620 × 620 mm | 1260 × 525 × 570 mm |
| Dimensions (max. column height) | 1680 × 620 × 620 mm | 1680 × 525 × 570 mm |
| Total weight (incl. battery) | Approx. 90 kg | Approx. 90 kg |
| Total DOF (excl. end effector) | 17 | 19 |
| Single arm DOF | 7 | 7 |
| Max. single arm payload | Approx. 3 kg | Approx. 3 kg |
| End effector options | 2-finger gripper / 3-finger hand / 3-finger tactile hand / 5-finger hand | 2-finger gripper / 3-finger hand / 3-finger tactile hand / 5-finger hand |
| Waist DOF | 2 | 2 |
| Waist range of motion | Z ±155°, Y −2.5° to +135° | Z ±155°, Y −2.5° to +135° |
| Column lifting speed | Approx. 60 mm/s | Approx. 60 mm/s |
| Max. mobility speed | — | 1.5 m/s |
| Chassis drive | — | Differential drive, 360° in-place rotation |
| Chassis sensors | — | LiDAR ×1, depth camera ×2, collision sensor ×2, low-obstacle sensor ×2 |
| Computing | 8-core high-performance CPU | 8-core high-performance CPU |
| Perception sensors | Head HD binocular camera ×1, wrist HD camera ×2 | Head HD binocular camera ×1, wrist HD camera ×2 |
| Connectivity | Wi-Fi 6, Bluetooth 5.2 | Wi-Fi 6, Bluetooth 5.2 |
| High computing module | Optional, e.g. Orin NX 16GB (100 TOPS) | Optional, e.g. Orin NX 16GB (100 TOPS) |
| Battery | Upper body 9Ah (quick-release) | Upper body 9Ah (quick-release) + chassis 30Ah (built-in) |
| Battery life | Approx. 2 hours | Approx. 6 hours |
| Manual controller / visualization computer | Yes / Yes | Yes / Yes |
| Intelligent OTA upgrade | Yes | Yes |
| Secondary development | Yes | Yes |
Arm payload varies with arm posture. Specifications may vary by configuration. Source: Unitree Robotics.
Service & Warranty
Every Unitree G1-D supplied by GulfNet Emirates – Drone & Robotic Systems comes with a 12-month manufacturer warranty on the complete unit and regional technical support. On-site deployment, data-platform setup and training are available on request.


